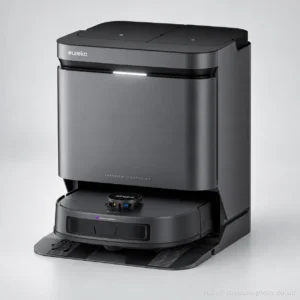
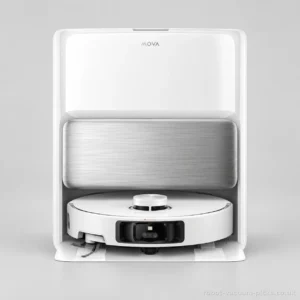
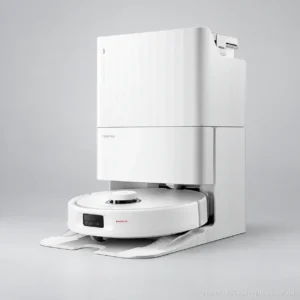
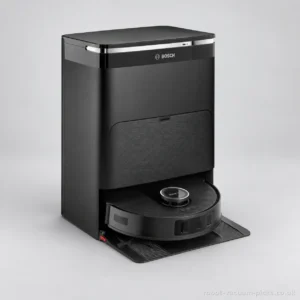
DJI Romo A
Top-ranked for charging time and suction power.
View analysis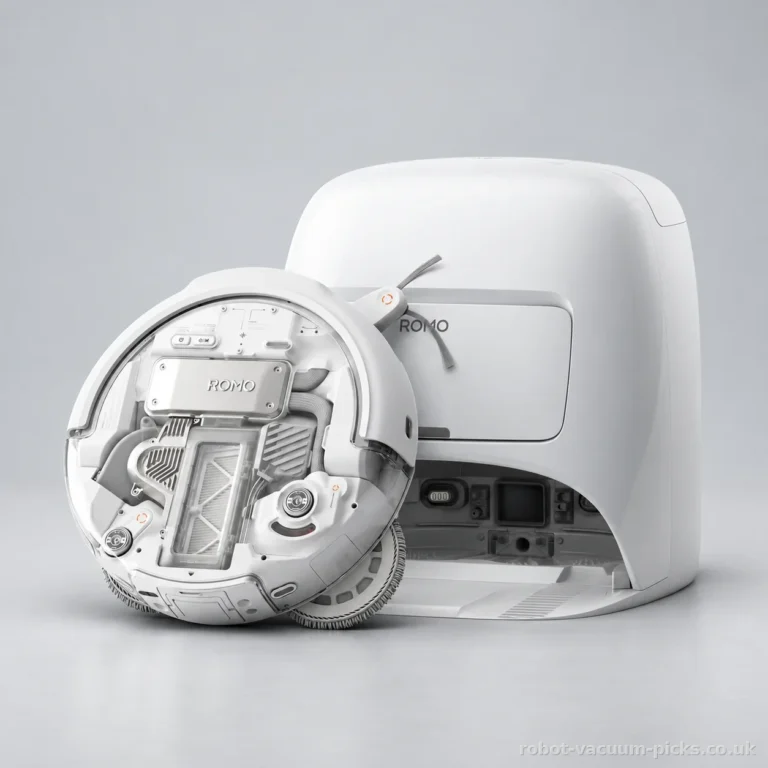 Our rankingsThe best robot vacuum cleaners46 robot vacuum cleaners
By function
By use
By station
Features and options
Guides to help you choose
Compare documented models using the available specifications. Use the filters to narrow this selection to your needs and budget.
Prices recorded from retailers are indicative: they may have changed since. The current price is the one shown by the retailer. No price is shown for models sold only on Amazon. Amounts converted from reference prices in euros using an exchange rate from a specified date.
Top-ranked for charging time and suction power.
View analysis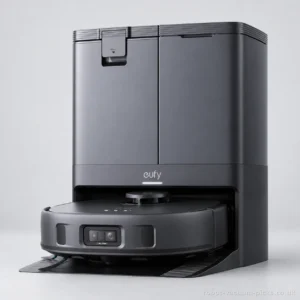
Top-ranked for battery life.
View analysis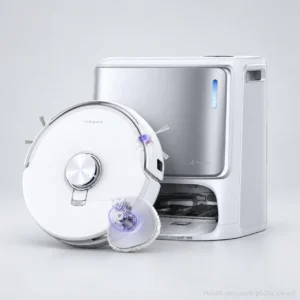
Top-ranked for max coverage.
View analysis| Rankings | Score | Price | Max coverage | Dustbin capacity | Noise level | Charging time | Battery life | Suction power |
|---|---|---|---|---|---|---|---|---|
| 1. DJI Romo A | 8.7/10 | £722 | 178 m² | 260 mL | 65 dB | 2.5 h | 180 min | n/a |
| 2. Eufy X10 Pro Omni | 8.8/10 | £390 | n/a | 330 mL | n/a | n/a | 210 min | 8000 Pa |
| 3. Narwal Freo Z10 Ultra | 8.8/10 | £509 | 300 m² | n/a | n/a | n/a | 150 min | n/a |
| 4. Roborock Qrevo MaxV | 8.3/10 | £520 | n/a | 330 mL | n/a | 4 h | 150 min | 7000 Pa |
| 5. Samsung Jet Bot Combo | 8/10 | n/a | n/a | 250 mL | 74 dB | 5 h | 180 min | 6000 Pa |
Rankings are based on our analysis scores, calculated from manufacturer specifications compared across the full catalogue.Our methodology.
This selection includes 9 analysed robot vacuum cleaners. Their average score is 8.4/10. Top rated: Eufy X10 Pro Omni, with 8.8/10.
Most featured brands: Bosch (1), DJI (1), Samsung (1).